Mitigating Cross Sensitivity and Drift in MEMS Accelerometer Signal Conditioning Chains
Front-end chopping and mechanical stress-relief routing isolate MEMS accelerometers from drift and cross-axis errors before digitization.
Topology
A differential capacitive microelectromechanical accelerometer resting on a quiet granite surface under atmospheric pressure at 25 degrees Celsius registers an output variance governed by Brownian motion, mechanical suspension anchor stress, and continuous front-end input leakage. The mechanical sense element pairs a suspended proof mass to fixed comb fingers, converting displacement along a sensitive axis into a capacitance imbalance. Off-axis acceleration forces the proof mass into asymmetric tilt modes, yielding parasitic capacitances that register directly on the primary axis as cross-axis error.
In industrial triaxial packages, cross sensitivity routinely lands between 1.0% and 3.5% of full-scale span before digital intervention. Thermal gradients distort the die attach interface, driving zero-g bias drift at rates between 0.1 mg per Kelvin and 1.5 mg per Kelvin.
The electronic conditioning interface translates these fractional femtofarad deflections into voltage levels while attempting to reject structural mechanical crosstalk and low-frequency flicker noise. The interface splits into three dominant circuit topologies: charge-amplifier topologies using continuous-time operational transconductance amplifiers, switched-capacitor charge-integrators, and electromechanical continuous-time sigma-delta feedback loops.
Front-End Transimpedance and Charge Conversion
Switched-capacitor charge integrators dominate contemporary commercial mixed-signal application-specific integrated circuits because they simplify clock synchronization and dynamic offset cancellation. The front end samples the differential sensor capacitances, denoted C1 and C2, by toggling reference excitation voltages at frequencies ranging from 100 kHz to 2 MHz. Charge packets equal to the product of excitation voltage and dynamic capacitance transfer into operational amplifier summing junctions, held virtually at ground.
Substrate parasitic capacitances at the bond pads and input pins load the summing junctions. These parasitics alter open-loop gain margins and amplify amplifier equivalent input voltage noise by the operational noise gain factor, defined by the ratio of total input capacitance to feedback capacitance. Continuous-time charge amplifiers avoid high-frequency switching transients by exciting the proof mass with anti-phase sinusoidal carriers, typically between 50 kHz and 500 kHz.
Synchronous demodulation down-converts the resulting high-frequency amplitude-modulated signal to baseband, shifting input stage 1/f noise outside the signal bandwidth.
Cross-axis capacitive coupling scales with aspect ratio tolerances in deep reactive-ion etching, converting perpendicular mechanical displacement into fractional femtofarad differential false signals on the primary sensing node.
Continuous-time sigma-delta architectures position the micromechanical proof mass directly inside an electromechanical feedback loop. The sense element acts as a second-order mechanical loop filter, followed by an electronic integrator, a flash analog-to-digital converter, and electrostatic pulse-density feedback actuators. Electrostatic forces restrain proof mass excursion to picometer ranges, eliminating mechanical spring non-linearities and suppressing cross-axis comb interlock effects.
Electrostatic feedback stability demands strict control over high-order phase margins, restricting dynamic range when wide input shock tolerances coincide with high open-loop quality factors.
The signal path faces fundamental noise boundaries. The mechanical noise floor derives from fluid squeeze-film damping and structural internal friction within the polysilicon flexures, formulated as the thermal equivalent acceleration noise density:
S_a = (4 k_B T omega_0) / (m Q)
Here k_B represents the Boltzmann constant, T represents absolute temperature in Kelvin, omega_0 represents the undamped mechanical resonant angular frequency, m represents the proof mass in kilograms, and Q represents the mechanical quality factor. Electronic thermal noise generated by the input transistors adds orthogonally to this mechanical noise floor. Achieving an input-referred noise density below 20 micro-g per square root Hertz requires proof mass values exceeding 0.5 micrograms alongside input stage transconductance values exceeding 500 microsiemens.
Low transconductance degrades signal-to-noise ratios, forcing signal conditioning chains to consume higher operational supply current.
The engineering team settles the topology trade-off by accepting higher front-end silicon area to suppress parasitic input loading.
Stiffness
Anisotropic etching profiles create mechanical cross-axis coupling before charge moves into the silicon front end. Deep reactive-ion etching produces sidewall scallop depths between 20 nanometers and 150 nanometers alongside deliberate vertical taper angles departing from true perpendicularity by 0.1 to 0.5 degrees. When an acceleration vector strikes orthogonal to the intended sensitive axis, this vertical taper generates out-of-plane and diagonal displacement vectors.
The proof mass twists on its suspension beams. Fingers intended to measure displacement solely along the x-axis experience non-uniform gap closures along the z-axis and y-axis.

Mechanical Suspension Anisotropy
Folded beam flexures isolate cross-axis modes by maintaining high structural rigidity along non-sensitive directions. The mechanical stiffness ratio between cross-axis compliance and primary-axis compliance governs intrinsic cross sensitivity:
K_cross = k_x / k_y
Etch non-uniformities across an eight-inch silicon wafer shift this ratio across die locations. Outer die exhibit asymmetric suspension widths due to plasma sheath deflection at the wafer periphery, degrading raw mechanical cross-axis rejection by up to 6 dB compared to central die. Thermal expansion mismatches between the silicon proof mass, glass or silicon capping substrates, and eutectic bonding layers create static internal pre-stress fields.
These internal stress fields alter mechanical spring rates as temperature shifts, causing resonant frequency drift and changing the mechanical transfer scale factor.
| Physical Mechanism | Coupling Path | Raw Cross Sensitivity Range | Post-Calibration Residual |
|---|---|---|---|
| Etch Taper Asymmetry | Proof mass asymmetric tilt | 0.8% to 2.2% of span | 0.08% to 0.15% |
| Comb Finger Edge Fringe | Cross-axis out-of-plane fringing fields | 0.3% to 0.9% of span | 0.04% to 0.08% |
| Die Attach Thermomechanical Bow | Substrate shear into anchor joints | 0.5% to 1.8% of span | 0.12% to 0.25% |
| Mold Compound Curing Shrinkage | Package asymmetric warpage | 0.4% to 1.4% of span | 0.09% to 0.20% |
Package architecture dictates long-term drift characteristics. Plastic dual flat no-lead enclosures subject silicon dies to epoxy molding compound curing shrinkage stresses exceeding 30 megapascals. Moisture absorption by the epoxy plasticizes the polymer matrix, shifting packaging stresses during field operation.
Operating environments with relative humidity cycling between 20% and 85% drive zero-g output shifts between 2 mg and 15 mg in uncompensated packages. Ceramic hermetic leadless chip carriers isolate environmental moisture, transferring low mechanical stresses to the die through soft silicone or gold-tin eutectic preforms.
Ceramic packaging escalates raw bill-of-materials costs while eliminating the polymer creep mechanisms that ruin long-term stability. A commercial buyer balances this packaging expense against the computational and calibration overhead needed to correct unstable packaging warpage over five-year deployment intervals.
The manufacturing floor absorbs uncalibrated structural cross sensitivity as an immediate yield loss whenever acceptance criteria fall below 0.5%.
Demodulation
Raw microvolt-level signals emerging from the mechanical sense element require active modulation to evade CMOS flicker noise corners, which sit between 5 kHz and 50 kHz in standard 0.18-micron mixed-signal processes. Phase-sensitive detection isolates valid acceleration signals from high-frequency clock feedthrough, parasitic substrate currents, and orthogonal quadrature waveforms. Quadrature errors stem from parasitic resistances in polysilicon interconnect traces and unequal capacitive coupling paths, generating an out-of-phase signal component up to forty times larger than the in-phase acceleration signal under zero-g conditions.
Phase-Sensitive Detection Mechanics
The front-end conditioning chain applies a reference clock phi_mod to drive the proof mass. The output of the continuous-time charge amplifier passes into a ring demodulator or a balanced Gilbert cell mixer, driven by an interrogation carrier phi_demod. Phase alignment between phi_mod and phi_demod dictates cross-axis and quadrature rejection.
A phase mismatch theta converts quadrature signals directly into baseband direct-current zero-g bias offsets according to the trigonometric relationship:
V_demod = V_sig cos(theta) + V_quad sin(theta)
When V_quad reaches 50 millivolts and theta drifts by 0.5 electrical degrees over temperature, the resulting baseband drift equals 436 microvolts. In a sensor with a sensitivity of 100 millivolts per g, this drift represents a 4.36 mg zero-g bias error. Phase errors arise from propagation delays across front-end transimpedance amplifiers, on-chip clock routing buffers, and temperature-dependent RC decay rates inside the sensing comb networks.
Dynamic offset cancellation relies on two distinct circuit techniques: correlated double sampling and operational amplifier chopper stabilization. Chopper stabilization routes the low-frequency signal through alternate inversion states before and after amplification, shifting the amplifier offset and 1/f noise spectrum up to the chopping frequency. The subsequent low-pass filter suppresses this high-frequency content, leaving a baseband signal devoid of intrinsic CMOS amplifier offset voltages.
Correlated double sampling functions as a reset-and-hold sequence. The stage samples amplifier offset and low-frequency noise during a preliminary phase onto a storage capacitor, subtracting it from the combined signal-plus-noise vector during the subsequent integration phase. This operation attenuates low-frequency flicker noise and eliminates static input offset voltages, but folds wideband white noise back into the baseband via sample-phase aliasing.
- Mechanical sense excitation delivers differential carrier voltages between 0.8 V and 3.3 V peak-to-peak into the shared proof mass node to establish charge balance.
- High-pass charge isolation strips static direct-current leakage currents through input blocking capacitance arrays without attenuating high-frequency displacement signals.
- Synchronous demodulation mixing folds modulated dynamic acceleration signals back to direct current using quadrature-suppressed phase clocks.
- Continuous baseband filtering suppresses residual carrier clock feedthrough and even-harmonic distortion products before analog-to-digital conversion stages.
Synchronous demodulation schemes demand dedicated phase-locked loops or on-chip self-calibration delay-locked loops to realign clock edges over thermal shifts. Phase tracking errors generate unrecoverable bias drift across industrial operating bands.
Chopper stabilization operating at 250 kHz attenuates CMOS 1/f amplifier noise up to the third harmonic while folding broad-spectrum thermal noise back into the baseband signal path.
Failing to suppress front-end quadrature phase skew leaves the post-digitization filters processing a false acceleration offset that shifts whenever supply voltages fluctuate.
Digitization
Analog-to-digital conversion stages dictate whether baseband signal purity reaches the host processor without bit-level distortion. Accelerometer analog front ends feed either incremental zoom analog-to-digital converters or continuous-time third-order sigma-delta modulators. Incremental converters run at lower oversampling ratios, providing rapid settling suited for multiplexed multi-axis architectures.
Multi-axis architectures switch one analog-to-digital converter across three physical sense axes through an analog multiplexer, introducing channel-to-channel crosstalk if charge residues linger on conversion sampling capacitors.
Modulator Geometries and Filtering
Discrete continuous-time third-order sigma-delta modulators oversample sensor outputs at ratios from 64 to 512, shifting quantization noise away from physical measurement bands. The discrete signal conditioning chain uses multi-bit feedback digital-to-analog converters paired with dynamic element matching algorithms to preserve linearity across full-scale spans. Quantization noise shaping produces a steep noise floor slope, leaving thermal Brownian motion and amplifier noise as the dominant limits on final resolution.
On-chip decimation filters execute down-sampling and high-frequency noise rejection. Cascaded integrator-comb architectures perform primary decimation without multiplier silicon area, followed by finite impulse response compensation filters that equalize high-frequency passband droop. Sinc3 filters yield high rejection at integer multiples of the sampling frequency, isolating high-frequency mechanical resonance spikes from aliasing back into baseband control bandwidths.
The finite impulse response filter introduces frequency-dependent group delay, calculated as:
tau_g = (N – 1) / (2 f_s)
Here N represents the filter tap count and f_s represents the output data rate in Hertz. In closed-loop vehicle stability control applications, a delay exceeding 2.5 milliseconds destabilizes high-speed feedback control networks. Reducing filter tap counts decreases phase lag while admitting broad-spectrum out-of-band vibrations into the digitized band.
High-g out-of-band acoustic or mechanical energy excites mechanical sensor resonances between 15 kHz and 35 kHz. Without steep antialiasing filters, non-linear mixing down-folds this acoustic energy into low-frequency false static acceleration readings, an operating vulnerability designated as vibration rectification error.
Analog input tracking dynamics govern multiplexed front ends. Incomplete settling during axis switching creates an artificial cross-coupling coefficient indistinguishable from mechanical comb taper errors. Signal conditioning chains require low output-impedance buffer amplifiers between the multiplexer and converter input stages to charge internal sampling arrays within allocated clock phases.
High-resolution converters achieve 20-bit raw resolution, yet board-level power supply noise coupling through reference pins degrades effective resolution down to 16 bits. Reference buffer circuits need power supply rejection ratios exceeding 80 dB up to 100 kHz to prevent switched-mode regulator ripple from inducing false periodic acceleration signals.
Under-filtering high-frequency mechanical resonant peaks injects rectified bias shifts into the digitized stream that no subsequent linear filtering can extract.
Calibration
Factory calibration strips remaining physical and electronic imperfections from the digitized output. The linear relationship linking actual physical acceleration vectors to digitized output codes conforms to a 3×3 sensitivity matrix multiplied by the mechanical input vector, summed with a 3×1 zero-g bias vector:
Y = S A + B + E
In this formulation, Y represents the 3×1 measured digital output vector, S represents the 3×3 sensitivity and cross-axis alignment matrix, A represents the 3×1 true input acceleration vector, B represents the 3×1 zero-g bias vector, and E represents the random white noise vector. Off-diagonal elements within matrix S capture mechanical comb misalignments, package mounting angular errors, and electrical channel cross-coupling.
Static Matrix Extraction Techniques
Extracting these parameters requires multi-position static tumbling evaluations inside the terrestrial 1 g gravitational field. Accelerometers mount to automated multi-axis rate tables inside environmental chambers. Orienting each axis precisely parallel and anti-parallel to the gravity vector exposes the sensor to predictable static reference loads of +1 g and -1 g across six orthogonal orientations.
- Six-position tumble routines mount the packaged part along positive and negative orientations of all three axes to isolate zero-g bias offsets from axial scale factors.
- Twelve-position dodecahedron static sweeps expose diagonal vectors to separate mechanical cross-axis terms from package-to-board tilt misalignments.
- Thermal soak stepping records output variations at -40 °C, +25 °C, and +105 °C to establish polynomial temperature coefficients for bias and sensitivity.
- Non-volatile memory burning writes derived polynomial coefficients directly into on-chip registers for real-time firmware correction.
The six-position routine isolates zero-g bias and axial scale factors, but lacks sufficient angular diversity to decouple true internal sensor cross sensitivity from exterior fixture mounting errors. Twelve-position or twenty-four-position calibration protocols apply known gravity projections simultaneously across multiple axes, providing the mathematical constraints required to resolve all nine components of matrix S using iterative least-squares optimization algorithms.
| Error Source | Typical Uncalibrated Error | Compensation Mechanism | Residual Calibrated Error |
|---|---|---|---|
| Zero-g Offset Bias | +/- 40 mg to +/- 100 mg | Factory lookup table or polynomial | +/- 2 mg to +/- 5 mg |
| Sensitivity Thermal Drift | +/- 1.5% to +/- 3.0% of span | Third-order thermal polynomial | +/- 0.15% to +/- 0.3% |
| Cross-Axis Coupling | 1.5% to 3.0% of span | Linear 3×3 cross-axis matrix | 0.1% to 0.25% |
| Non-Linearity | 0.3% to 0.8% of full scale | Second-order piecewise correction | 0.05% to 0.1% |
| Long-Term Solder Drift | +/- 5 mg to +/- 20 mg | System-level auto-zero routine | +/- 1 mg to +/- 3 mg |
Thermal zero-g bias drift follows non-linear polynomial trajectories dictated by silicon piezoresistive effects and die attach glass transition relaxation points. On-chip temperature sensors provide real-time thermal updates, feeding compensation engines evaluating third-order polynomials:
B(T) = B_0 + T_c1 (T – T_0) + T_c2 (T – T_0)^2 + T_c3 (T – T_0)^3
The coefficients B_0, T_c1, T_c2, and T_c3 reside in integrated one-time programmable or electrically erasable programmable read-only memory cells. Silicon die temperature does not match ambient PCB temperature during rapid thermal transitions, generating transient compensation errors. Thermal gradients through the package induce mechanical stresses that distort the sensor combs before the internal thermal diode registers the temperature shift.
Dynamic thermal lag introduces loop errors during environmental thermal shocks, temporarily inflating zero-g bias errors by up to an order of magnitude.
Factory multi-temperature calibration represents the single largest cost driver in precision MEMS production, often matching or exceeding the total front-end silicon fabrication expense. High-volume consumer parts bypass multi-temperature chamber cycles, relying on single-temperature trims at 25 °C and generic wafer-lot polynomial models, leaving the buyer to absorb wider operational thermal drift windows.
Omitting thermal cross-term calibration forces downstream navigation algorithms to misinterpret lateral vehicle maneuvers as false changes in vertical elevation.
Anchor
Packaging and board mounting establish the physical boundary conditions for long-term measurement stability. Printed circuit board solder reflow exposes the accelerometer package to thermal peaks reaching 260 degrees Celsius under standard lead-free SAC305 assembly profiles. Differential thermal expansion between the copper-clad FR4 substrate and the silicon package generates permanent post-solder anchor stresses.
The FR4 laminate expands at 14 to 17 parts per million per Kelvin, while the silicon die expands at 2.6 parts per million per Kelvin. The solder joints freeze this expansion mismatch as the board cools, inducing package warpage that shifts the factory-calibrated zero-g bias by 10 mg to 50 mg.
Mechanical Stress Isolation Geometries
Circuit board layout choices dictate how efficiently external mechanical strains bypass the fragile internal sensing combs. Accelerometers positioned near circuit board mounting screw holes, heavy daughtercards, or structural edge connectors experience mechanical strains whenever external enclosures flex. Tensile and compressive board strains propagate directly through solder fillets into the package substrate.
Board designers isolate sensitive sensing units by milling relief slots through the FR4 material around the sensor perimeter. Routing a U-shaped or spiral slot isolates the part onto a cantilevered or bridge-suspended tab, attenuating board-level flexural stresses by up to 18 dB. Mechanical mounting layout demands clean trace symmetry.
Asymmetrical solder pad geometries or non-uniform solder mask clearances cause surface tension imbalances during reflow cooling, tilting the package by fractions of an angular degree. A physical package tilt of 0.1 degrees projects the ambient 1 g vertical gravitational vector onto horizontal axes, creating a 1.74 mg static bias offset.
Under IPC-A-610 standards, non-symmetric solder joint fillet heights across opposing package pads generate localized twisting moments that shift zero-g bias offsets beyond factory test limits.
Conformal coatings introduce secondary drift mechanisms. Polyurethane, acrylic, or silicone coatings applied for environmental moisture protection cure across package perimeters, generating compressive mechanical hoop stresses as the polymers age and outgas. Thick coatings bridge the relief gap beneath land grid array packages, converting localized moisture expansion into mechanical package distortion.
For extreme drift-critical designs, designers place low-modulus underfills beneath leadless packages to damp high-frequency vibration modes without transferring aggressive curing shrinkage stresses to the active silicon element.
Skipping board strain relief routing allows external enclosure assembly torques to degrade calibrated bias stability limits.
Arbitration
High-reliability designs decouple the measurement chain from single-sensor physical limits by operating diverse redundant sensing elements. Multi-die arrays cross-reference physical capacitive sensors with piezoresistive elements or optomechanical cells, balancing distinct drift and failure mechanisms across physical regimes. While capacitive combs yield high sensitivity and ultra-low noise floors, they remain vulnerable to acoustic resonance degradation and squeeze-film thermal damping shifts.
Piezoresistive sensing beams possess low output impedance and immune comb dynamics, operating reliably through high-g shock strikes up to 20,000 g while exhibiting higher thermal zero-g drift.
Real-Time Algorithmic Compensation
System microcontrollers run dynamic error models alongside physical sensor feeds, processing real-time environmental context to adjust conditioning parameters. Extended Kalman filters and complementary fusion algorithms combine accelerometer outputs with angular rate gyro data to isolate steady-state gravity vectors from translational acceleration transients.
Zero-velocity updates provide drift arbitration for inertial navigation systems. When peripheral condition flags confirm the platform has reached absolute rest, the conditioning firmware updates static zero-g bias estimates, neutralizing long-term solder relaxation and moisture drift. In moving vehicles, kinematic constraints prevent sustained lateral slip under normal tractive limits, allowing the algorithm to isolate and correct lateral accelerometer bias drift during sustained straight-line travel.
Auto-calibration algorithms leverage geometric spatial invariants. A triaxial accelerometer operating in a static or uniform velocity state must register a total acceleration magnitude precisely matching the local terrestrial gravity vector:
A_x^2 + A_y^2 + A_z^2 = |g|^2
Deviations from this spherical manifold across multiple random static orientations provide the loss function for recursive gradient descent algorithms. The internal firmware continuously extracts nine parameter correction values, tracking sensitivity, cross-axis alignment, and zero-g offsets without requiring laboratory tilt fixtures. This background optimization requires rich angular excitation across the unit sphere.
If an asset operates purely along a flat two-dimensional plane, the optimization becomes mathematically ill-conditioned, locking recursive estimators into false parameter minima.
Micro-machined thermal heating zones integrated directly onto the sensor capping layer maintain the silicon core at an elevated, constant operating temperature, such as 60 degrees Celsius, regardless of exterior ambient fluctuations. This physical oven-stabilization eliminates thermal drift modes at the source, exchanging a steady 15 to 40 milliwatt power consumption overhead for near-complete immunity against exterior thermal gradients.
The engineering team confirms that continuous auto-zero routines operate safely only when application duty cycles supply absolute zero-velocity resting periods.
Allocation
Selecting an accelerometer signal conditioning chain locks the bill of materials into specific wafer foundries, packaging facilities, and licensing ecosystems. The global supplier pool splits along clear geographical and architectural boundaries. Monolithic single-die solutions, which integrate MEMS comb structures and mixed-signal CMOS circuits on a single wafer layer via high-temperature processes, remain concentrated within vertically integrated device manufacturers operating fabrication facilities in Japan, Europe, and the United States.
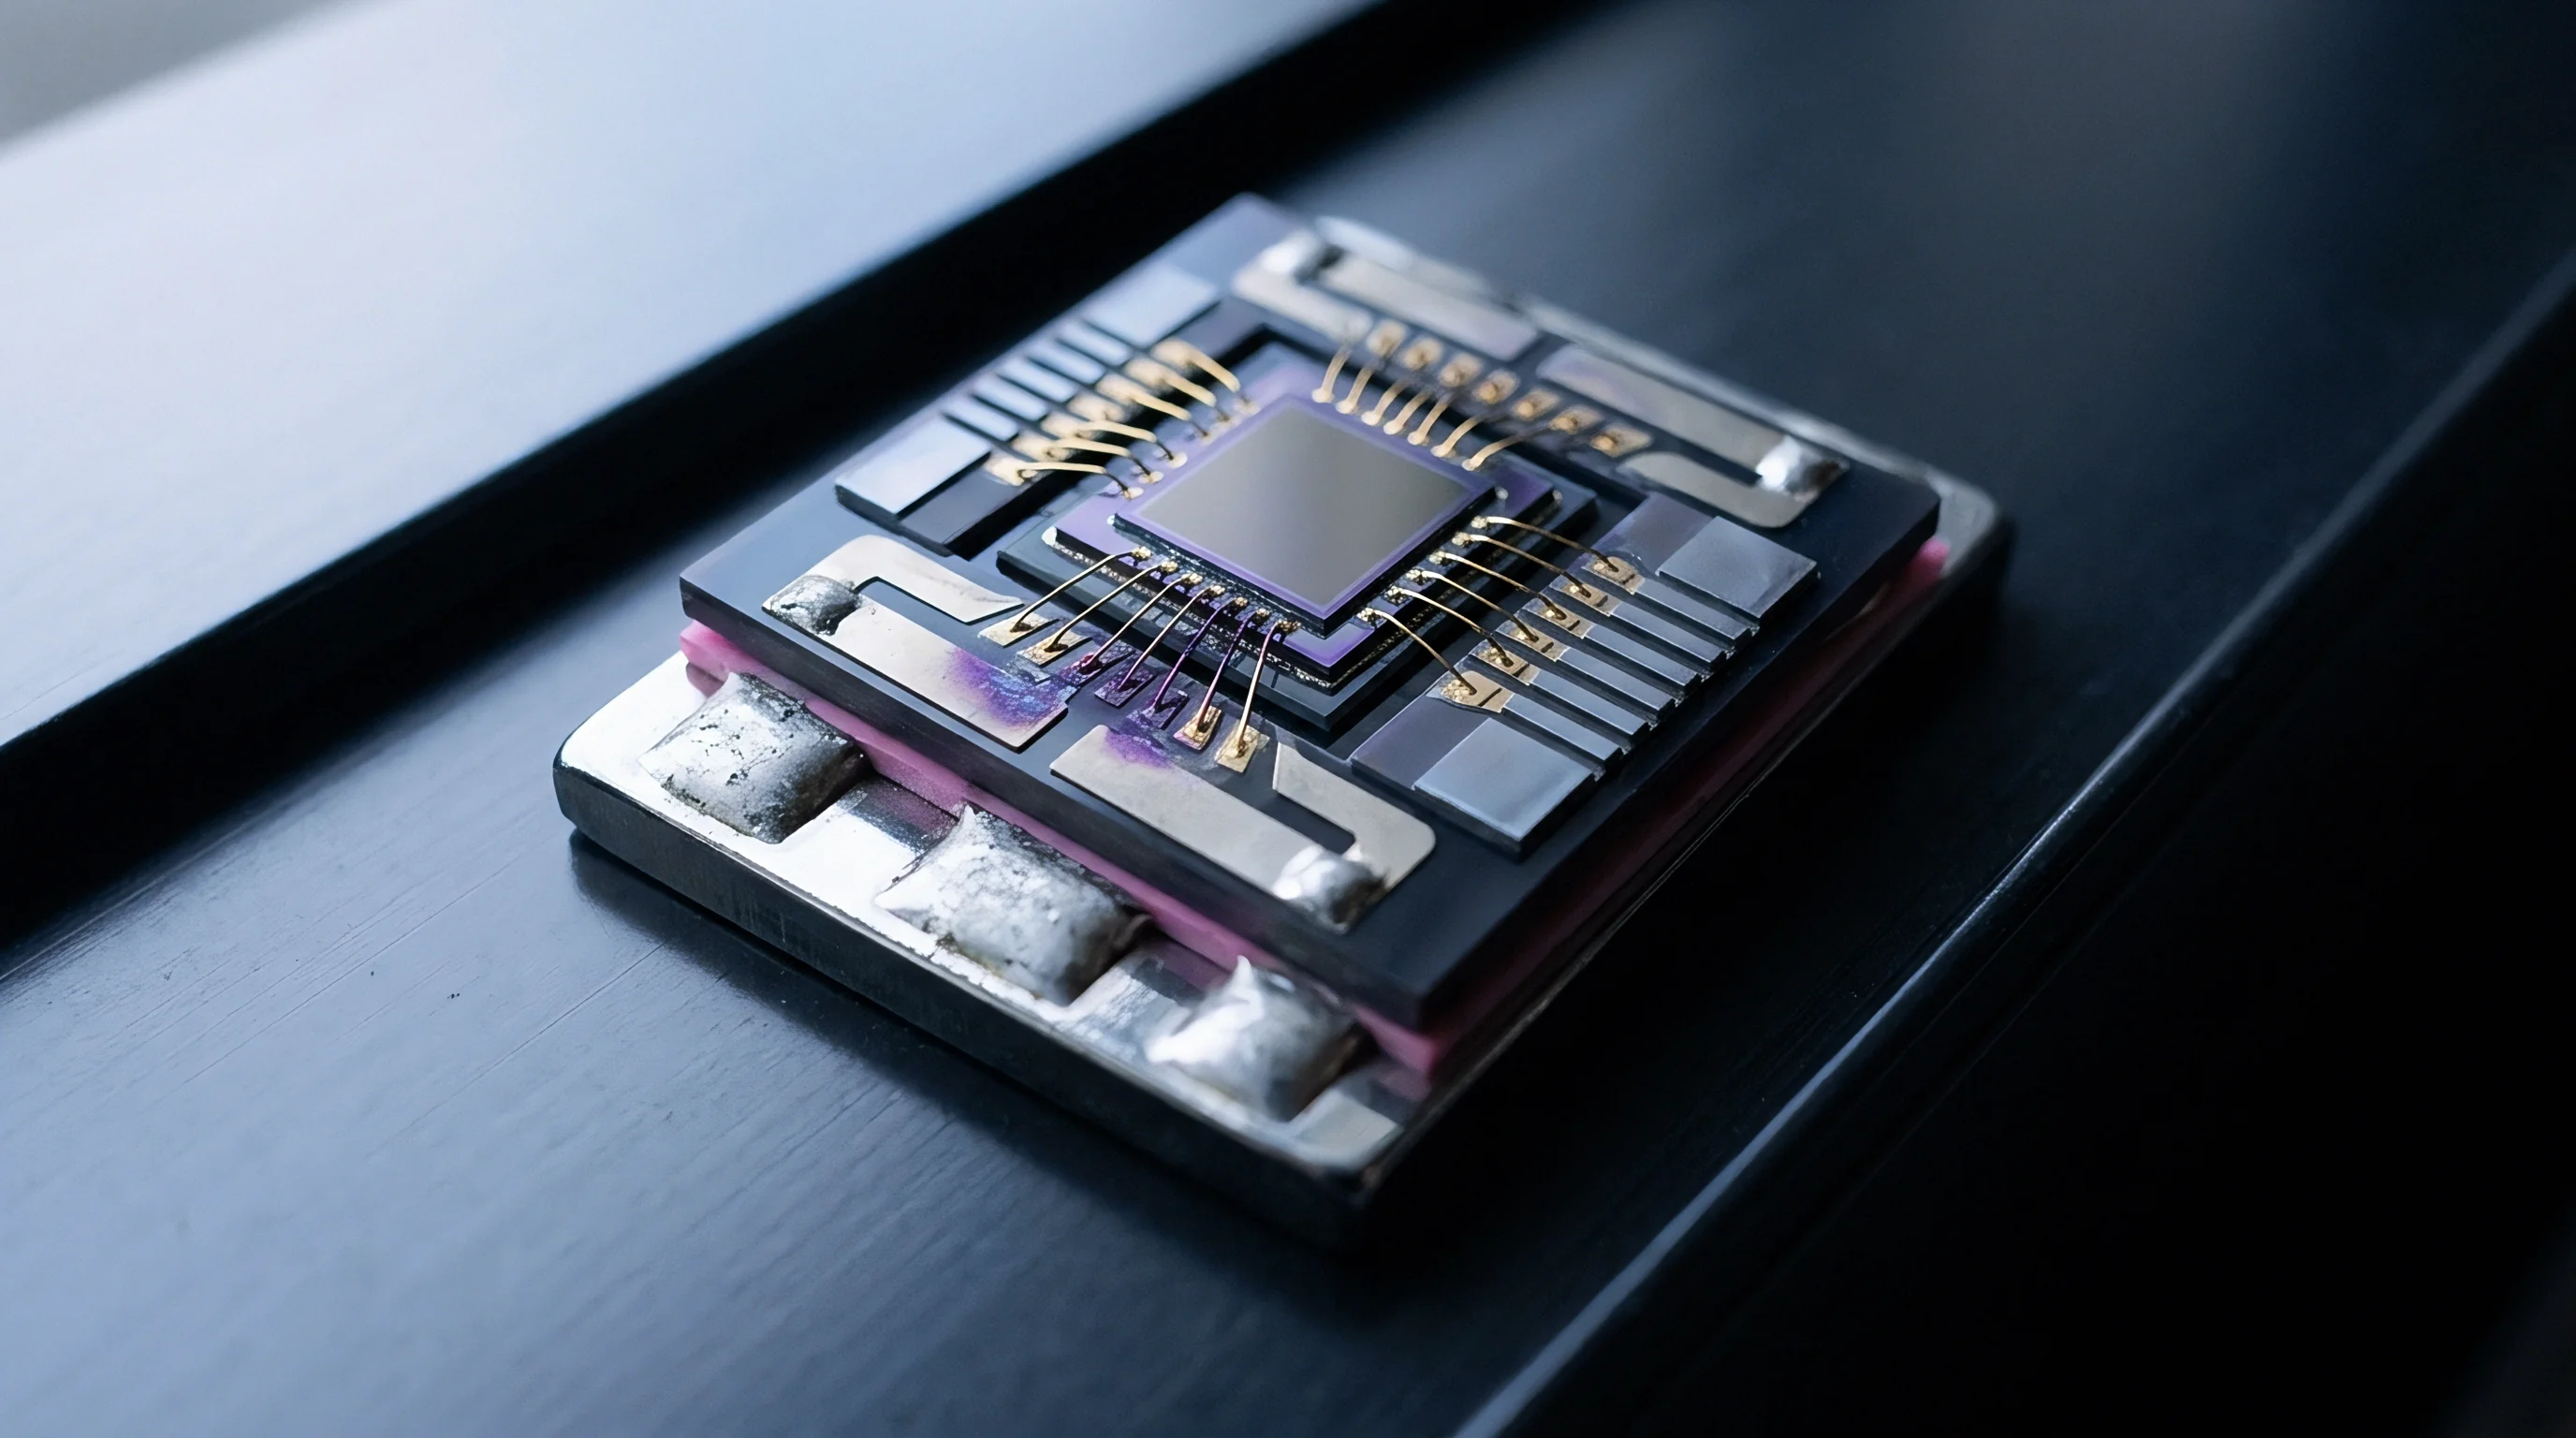
Two-chip systems combine an optimized high-aspect-ratio pure MEMS micromachining die with a standard mixed-signal CMOS application-specific integrated circuit, connecting the two inside a single package via sub-millimeter wire bonds or through-silicon vias. This modular split opens the supply chain to specialized MEMS foundries concentrated in Taiwan, Singapore, and mainland China, operating alongside independent packaging houses.
Procurement Vulnerabilities and Second Sourcing
Specifying a monolithic part provides ultra-low parasitic input capacitance and compact package footprints, but locks procurement into sole-source fab dependencies. A supply interruption at a single automotive-qualified European fab forces an eighteen-month redesign cycle to validate replacement ASIC front-end silicon, requalify AEC-Q100 thermal performance, and rebuild board-level strain-relief tooling. Two-chip architectures provide design-level flexibility, permitting an engineering team to swap the mixed-signal conditioning ASIC while preserving the mechanical sensor die, or vice versa, provided interface bond pad capacitances match within acceptable noise-gain design margins.
- AEC-Q100 Grade 1 qualification enforces operational reliability from -40 °C to +125 °C across 1,000 thermal cycles, eliminating standard commercial consumer-grade parts from consideration.
- AEC-Q103-002 standards define specific fault-grading metrics and lifetime drift tolerances for MEMS automotive motion and vibration sensors.
- Lead time volatility for specialized automotive high-g and industrial grade accelerometers historically expands past 36 weeks during semiconductor allocation cycles.
- Pin-to-pin drop-in alternatives rarely exist between disparate MEMS suppliers, because proprietary register maps, internal clock configurations, and interrupt architectures prevent software interchangeability.
Procurement teams evaluate not only bare die pricing, which ranges from $0.35 for high-volume consumer three-axis parts to $45.00 for hermetic high-stability tactical sensors, but the fully burdened cost of ownership. Burdened costs incorporate incoming quality inspection lot screening, production-line tumble calibration cycles, firmware driver maintenance, and field-failure warranty exposures driven by packaging drift. Sourcing strategies balance component unit costs against downstream factory floor test times, where every additional second spent inside a precision thermal tumbling chamber adds direct capital depreciation expense to the final electronic assembly.
The contract manufacturer waives component warranty liability whenever reflow peak temperatures violate the component packaging moisture sensitivity level handling window.