Modeling Non-Linear Base Motion Coupling in High-Latitude Ground Alignment Error Budgets
High-latitude ground alignment error budgets require explicitly modeling second-order sculling and vibro-pendulous base motion rectifications to prevent false bias growth.

Pole
Ground gyrocompassing finds true north by isolating the horizontal component of Earth’s spin. Near the equator and throughout mid-latitudes, that vector is strong enough for standard optical and mechanical gyros to resolve cleanly. Moving poleward, however, the horizontal rate falls off with the cosine of latitude.
By 70 degrees north, the horizontal rate is down to 5.14 degrees per hour. Past 85 degrees north, it slips below 1.31 degrees per hour, disappearing into the noise floor of tactical and navigation grade inertial measurement units.
Platform motion compounds this extraction problem. Stationary vehicles, mobile radar masts, and missile launchers still encounter substantial environmental motion on the pad: wind gusts, idling engines, onboard personnel, and shifting ice or wave slap introduce continuous angular vibration and linear accelerations. These inputs span 0.1 Hertz to well over 100 Hertz.
When high-frequency motion meets sensor non-linearities, the dynamics rectify into steady low-frequency rate biases. At polar latitudes, an uncorrected bias of just 0.01 degrees per hour throws off the computed heading by several degrees.
An uncompensated cross-axis angular vibration at 15 Hertz producing 0.5 degrees per second peak velocity induces a rectified drift exceeding 0.04 degrees per hour in optical gyroscopes.
Geometric signal strength decays directly with increasing latitude.
An alignment error budget must tackle two problems at once: the vanishing horizontal Earth rate and the spurious heading signals produced when base motion rectifies across the sensor cluster. Accelerometers reading the gravity vector contend with cross-axis coupling, scale-factor non-linearities, and vibro-pendulous errors that skew the perceived tilt. Meanwhile, gyroscopes experience coning and sculling effects that masquerade as genuine rotation along horizontal and vertical axes.
If the alignment filter cannot distinguish motion rectification from true Earth rotation, azimuth drift grows without bound.
Earth Rate Signal Attenuation Mechanics
The total terrestrial rotation rate of 15.041 degrees per hour resolves into horizontal and vertical components determined by local latitude. Ground alignment routines establish azimuth by projecting gyro measurements onto the level plane defined by accelerometer tilt angles. As latitude climbs, heading sensitivity deteriorates with the secant of latitude as the measurable horizontal projection shrinks.
| Latitude Degrees | Horizontal Rate Deg Per Hr | Vertical Rate Deg Per Hr | Maximum Gyro Bias For 0.1 Deg Heading | Heading Noise Amplification Factor |
|---|---|---|---|---|
| 0 | 15.0410 | 0.0000 | 0.0262 Deg Per Hr | 1.00 |
| 45 | 10.6356 | 10.6356 | 0.0185 Deg Per Hr | 1.41 |
| 70 | 5.1444 | 14.1338 | 0.0090 Deg Per Hr | 2.92 |
| 80 | 2.6118 | 14.8123 | 0.0045 Deg Per Hr | 5.76 |
| 85 | 1.3108 | 14.9838 | 0.0023 Deg Per Hr | 11.47 |
| 89 | 0.2625 | 15.0387 | 0.0005 Deg Per Hr | 57.30 |
Near the poles, the usable horizontal rotation vector collapses toward zero.
Heading variance formulas explain why platform motion completely dominates the polar error budget. Azimuth estimation uncertainty scales with gyro bias error divided by Earth rate times the cosine of latitude. At 85 degrees north, an in-run bias drift that produces a negligible 0.05 degree heading error at the equator expands to 0.6 degree.
If uncompensated base motion injects an additional bias of similar size, the alignment filter cannot converge within acceptable operational windows.
Overlooking non-linear motion rectification during high-latitude alignment invites gross navigation failure, releasing vehicles into transit with uncalibrated heading errors exceeding five degrees.
Coupling
Inertial sensing elements exhibit distinct higher-order dynamics when driven simultaneously along multiple axes. Flexure bending and pickoff misalignments cause linear accelerometers to register spurious cross-axis accelerations. Gyroscopes pick up linear acceleration through mechanical imbalances or photo-elastic distortion across optical paths.
When broadband vehicle vibration excites several axes at once, these cross-sensitivities cross-multiply, generating steady DC rate and tilt biases.
Coupled dynamic errors accumulate rapidly across high-latitude operating bands.
Vibro-pendulous torque in pendulous accelerometers is among the most damaging conversion mechanisms during stationary alignment. If angular oscillations around the sensor output axis coincide with linear accelerations along the pendulous axis, proof-mass displacement rectifies into a steady DC acceleration. The Kalman filter mistakes this offset for genuine gravity tilt and miscalculates the local level.
That tilt error then leaks Earth’s large vertical rotation component into the horizontal plane, corrupting the heading solution.
- Vibro Pendulous Rectification occurs when angular oscillation about the output axis coincides with synchronous acceleration along the pendulous axis, shifting the computed horizontal reference.
- Cross Axis Scale Factor Asymmetry develops when mechanical compliance differs under positive versus negative loads, rectifying symmetric vibration into a false gravity bias.
- G Sensitive Gyro Drift originates from center-of-mass offsets in mechanical gyros or photo-elastic stress within optical paths under linear load, generating rate errors driven directly by vehicle vibration.
- Angular Acceleration Output Coupling occurs when dynamic angular inputs saturate the linear response band of internal control loops, producing low-frequency bias anomalies.
Dynamic phase lag across processing channels feeds persistent rate drift.
Size-effect errors present a related kinematic trap. Because sensing elements within an IMU cannot occupy the exact same physical point, individual accelerometers are separated by several centimeters. Angular platform motion therefore induces local centripetal and tangential accelerations that differ at each sensor location.
Unless navigation software explicitly maps these lever-arm separation vectors during dynamic motion, the computed translational accelerations develop persistent rectified offsets.
While internal digital filtering is specified to strip out motion-induced disturbances above 50 Hertz, high-frequency vibration regularly intermodulates with sampling clock jitter to fold uncompensated low-frequency bias directly back into the alignment band.
Kinematics
Tracking base-motion rectification demands modeling sensor dynamics well past linear scale factors and static bias. High-latitude error models require second-order kinematic formulations that explicitly capture angular coning, velocity sculling, and quadratic accelerometer non-linearities. These kinematic corrections process high-rate sensor data into compensated velocity and angle increments before data reaches the covariance update loops.
Coning arises when orthogonal sensor axes oscillate with a ninety-degree phase difference. Even when net angular displacement averages out to zero over a complete cycle, the third axis traces an open geometric path that accumulates a net rotational increment. This kinematically generated drift corrupts azimuth estimation during persistent platform rock or sway.
Per MIL-STD-810H environmental profile limits, platform vibration profiles between 10 Hertz and 500 Hertz require high-speed coning integration rates of at least 1000 Hertz to prevent unmodeled heading drift exceeding 0.01 degrees per hour.
Uncompensated sculling forces distort the estimated platform tilt.
Sculling is the translational analogue to coning, appearing when angular rate about one axis coincides with linear acceleration along a perpendicular axis. Computing the cross products over discrete intervals requires high-frequency updates. If sculling integration falls below structural resonance frequencies, the resulting uncompensated velocity increments distort the leveled gravity reference.
- Sample tri-axial angular rate outputs and linear acceleration vectors at a minimum frequency of 1000 Hertz to capture high-frequency base motion components.
- Calculate discrete angular motion increments and velocity increments over the high-rate sampling interval.
- Compute the discrete coning correction vector using cross-products of consecutive angular increment vectors.
- Compute the discrete sculling correction vector using cross-products of angular increments and velocity increments across adjacent sub-intervals.
- Apply spatial size-effect transformation matrices to correct linear acceleration readings for radius vectors relative to the center of navigation.
- Evaluate second-order accelerometer non-linearity coefficients against squared acceleration inputs to isolate rectified bias terms.
- Deduct motion rectification vectors from input arrays before executing low-rate Kalman filter measurement updates.
High-frequency base vibration drives continuous scale factor shifts.
Comprehensive accelerometer formulations combine nominal scale factors with cross-axis coupling terms and second-order acceleration sensitivities. Measured acceleration along axis i reflects both direct input and these higher-order dynamic terms.
| Coupling Mechanism | Governing Mathematical Expression | Typical Value Range | Alignment Impact At 80 Deg Latitude |
|---|---|---|---|
| Coning Rectification | Half Integral of Angular Rate Cross Product | 0.001 to 0.05 Deg Per Hr | Direct Azimuth Bias Growth |
| Sculling Rectification | Half Integral of Angle and Acceleration Cross Product | 10 to 150 Micro-g | False Tilt and Gravity Misalignment |
| Vibro-Pendulous Error | K-vp Times Acceleration Product Along Pendulous and Output Axes | 5 to 50 Micro-g Per g-Squared | Horizon Tilt Shift corrupting Gyro Compass |
| Gyro Anisoelasticity | D-g Times Linear Acceleration Product Along Orthogonal Axes | 0.005 to 0.08 Deg Per Hr Per g-Squared | Low-Frequency False Drift Rate |
| Size-Effect Offset | Angular Rate Cross Rate Cross Position Vector | 2 to 30 Micro-g | Dynamic Velocity Noise Growth |
Mechanical sensing elements flex and deform under continuous dynamic load.
Unmodeled acceleration offsets accumulate steadily over time, presenting the Kalman filter with a persistent bias it cannot separate from true local gravity. Incorporating these second-order dynamic corrections directly into early signal processing stages is essential for high-latitude gyrocompassing.
Standard procurement specifications under IEEE 1554 for inertial sensor signal processing state that omitting dynamic sculling compensation at or above 1 Kilohertz invalidates published accelerometer scale factor stability bounds in high-vibration operating environments.

Allocation
Developing a ground alignment error budget means dividing allowable heading error between sensor bias, mounting geometry, thermal gradients, and non-linear motion coupling. At low latitudes, static sensor bias stability accounts for up to 80 percent of the error budget. Near the poles, where the horizontal Earth rate signal attenuates sharply, non-linear base motion coupling can easily consume up to 60 percent of the total allowable variance budget.
Unmodeled thermal transients directly corrupt computed heading accuracy.
Alignment filters model error states via linear differential equations, typically tracking errors in position, velocity, attitude, and sensor biases. When non-linear motion rectification occurs, it injects deterministic errors that violate the white-noise assumptions underlying the filter’s updates. Misinterpreting these rectified offsets as genuine gyro drift or tilt, the filter deflates its covariance estimates prematurely, yielding overconfident heading solutions that fail to converge.
Allocating more than 20 percent of an alignment error budget to uncompensated non-linear motion coupling guarantees filter divergence when operating north of 75 degrees latitude.
Standard linear filtering cannot resolve unmodeled dynamic phase lag.
Sensitivity analysis shows how variance propagates through system dynamics as latitude rises. In the error transition matrix, the off-diagonal coupling term between horizontal velocity error and heading error scales inversely with horizontal Earth rate. Toward polar latitudes, this term acts as a massive gain multiplier, inflating any residual velocity error from accelerometer sculling into large azimuth errors.
- Base Motion Spectral Identification requires mapping platform vibration modes across 0.1 Hertz to 500 Hertz under live operational conditions including engine idle and wind loading.
- High Rate Sampling Verification demands confirming that sensor processing pipelines execute coning and sculling integration at sample rates at least ten times higher than the highest structural resonance frequency.
- Cross Axis Compensation Mapping entails measuring individual sensor second-order rectification coefficients across the full thermal operating envelope prior to software integration.
- Kalman State Augmentation calls for adding second-order acceleration and rate-squared coupling states into the alignment filter when base motion spectral density exceeds background levels.
- Covariance Floor Tuning involves setting artificial process noise lower bounds to prevent the alignment filter from locking onto false heading solutions driven by rectified base motion.
Chassis isolation suppresses high-frequency structural resonance peaks.
Maintaining filter convergence requires balancing offline calibration against online stochastic estimation. Factory procedures map static scale factor and axis misalignments into correction matrices, while real-time kinematic algorithms strip out coning and sculling effects before raw inputs reach the Kalman measurement vector.
When base-motion spectra coincide with vehicle structural resonances, mechanical isolation must attenuate high-frequency energy so firmware routines can manage residual low-frequency dynamics.


Chamber
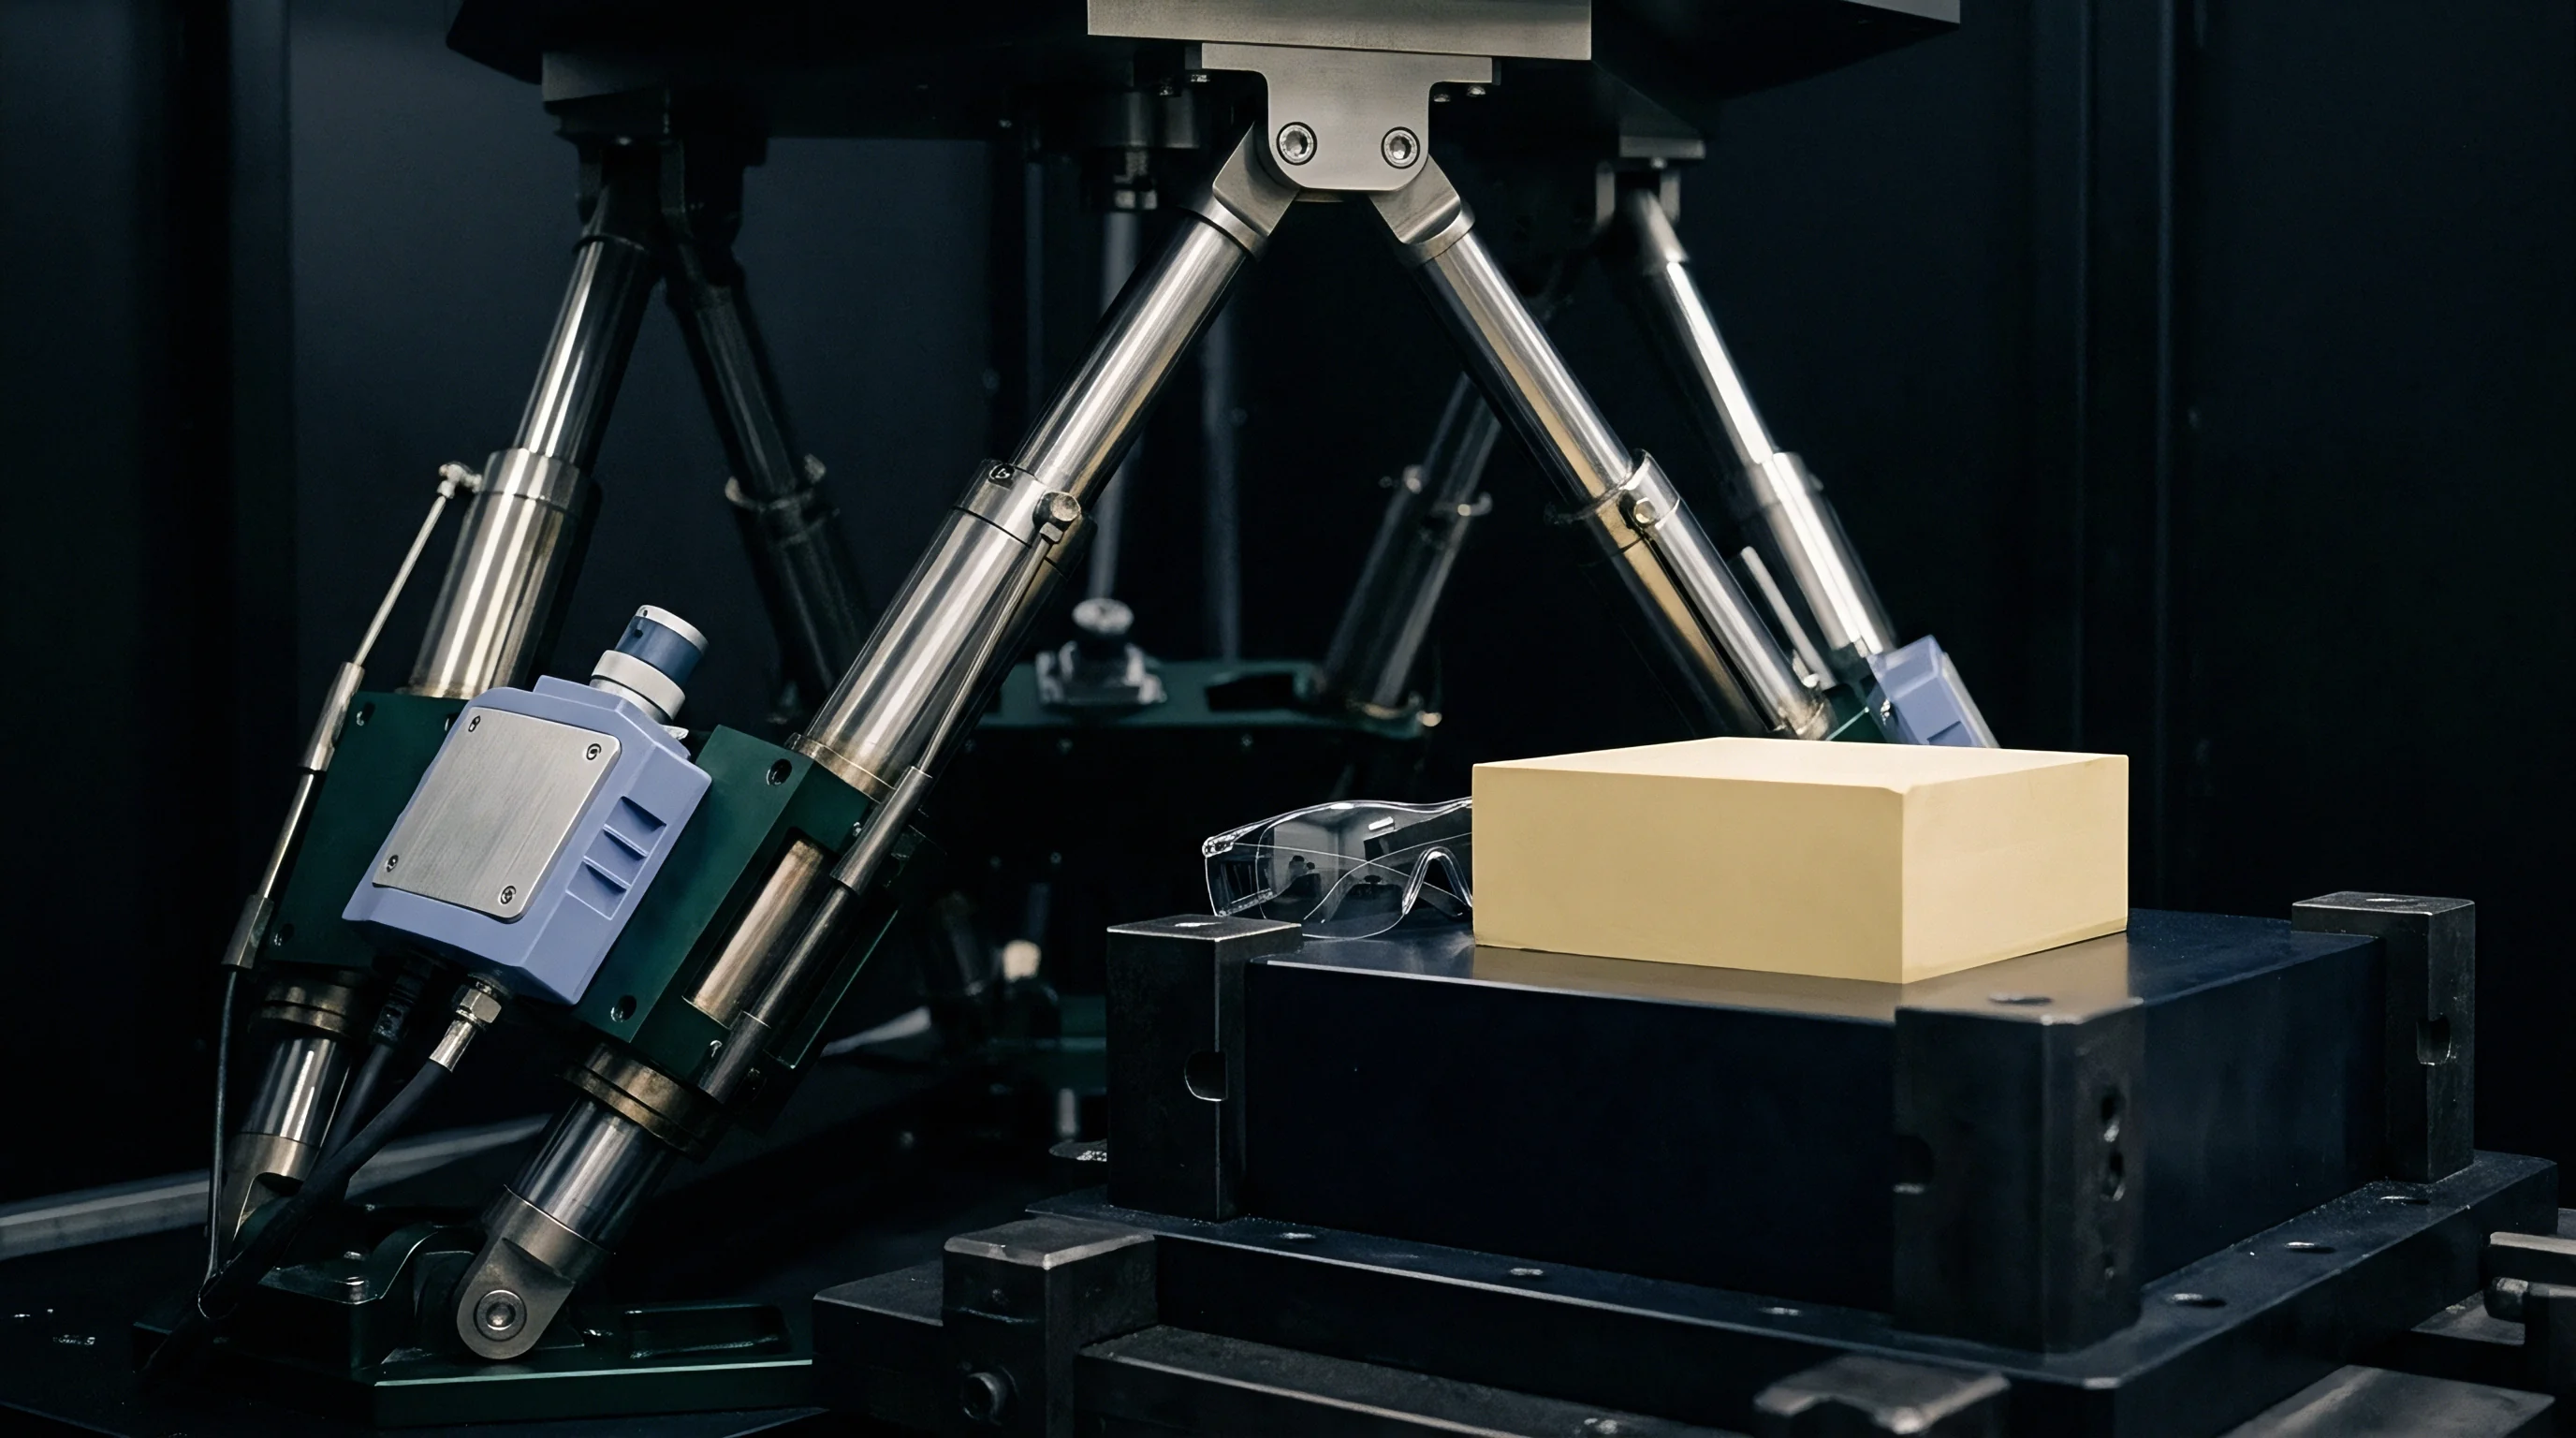
Validating dynamic error models requires multi-axis rate tables inside environmental chambers. Static multi-position tests on vibration-isolated pads establish baseline bias and scale factors, but they reveal none of the second-order rectification mechanisms triggered by real vehicle dynamics. Multi-axis test tables reproduce operating environments by superimposing continuous rates, sinusoidal vibration sweeps, and random vibration across the operational temperature range.
Digital quantization noise introduces latency into compensation loops.
Test fixturing demands strict rigidity during dynamic profiling to ensure mount resonances do not pollute calibration data. Accelerometers run on dual-axis centrifuges and linear vibration shakers to extract cross-axis sensitivity matrices and second-order coefficients. Gyroscopes undergo angular sweeps from 1 Hertz to 200 Hertz to evaluate coning compensation and quantify g-sensitive drift terms.
Bench testing on three-axis rate tables demonstrates that unmodeled structural resonances inside sensor chassis double the effective vibro-pendulous error coefficient between 40 Hertz and 80 Hertz.
Gimbal mount compliance distorts high-frequency dynamic readings.

Which Motion Profiles Reveal Dynamic Scale Factor Non-Linearity?
Isolating second-order non-linearities requires profile designs that decouple specific error coefficients without exciting collateral cross-coupling paths. Linear multi-frequency sweeps characterize accelerometer scale-factor linearity under load, while angular rate sweeps expose optical path saturation and dither lock-in boundaries in ring laser gyroscopes. Applying angular oscillation across two axes alongside linear vibration on the third reveals cross-axis rectification terms directly.
Thermal cycling during dynamic testing introduces further mechanical shifts. Internal mounts and flexures distort under temperature swings, rotating sensor input axes by tens of arcseconds. A shift of just 10 arcseconds under 1 g of continuous baseline vibration generates an apparent accelerometer bias shift of 48 micro-g ~ enough to consume the entire polar alignment allowance.
Which test profile provides sufficient observability to decouple structural chassis resonance from true optical ring laser gyro g-sensitivity during sub-zero thermal sweeps?
Trade
Selecting inertial sensors for high-latitude ground alignment involves balancing core physics against package volume, unit cost, and supply-chain maturity. Ring Laser Gyroscopes, Interferometric Fiber Optic Gyroscopes, and tactical Micro-Electro-Mechanical Systems present fundamentally different error profiles under dynamic base excitation. Sourcing choices must match each sensor’s physical limits against arctic operating constraints.
Cross-axis sensitivity often remains uncompensated across broader operational bandwidths.
Ring Laser Gyroscopes provide exceptional scale-factor stability and negligible g-sensitivity, maintaining their standing as the benchmark for high-latitude gyrocompassing. Their mechanical rigidity limits internal chassis resonance under base motion. Conversely, bulk, electrical draw, and high fabrication costs restrict them on lightweight tactical mounts.
Interferometric Fiber Optic Gyroscopes deliver comparable bias stability and survive severe shock without moving parts, yet their fiber coils exhibit photo-elastic strain and sensitivity to thermal gradients that induce transient bias errors during fast temperature ramps.
- Transduction Physics Suitability dictates matching the underlying sensor mechanism to expected platform dynamics so rectification does not mask the diminished polar Earth rate signal.
- Second Source Availability requires identifying alternate optical suppliers or silicon foundries capable of delivering drop-in sensor dies built to identical pinout and interface standards.
- Thermal Compensation Complexity accounts for the software overhead and factory calibration time required to characterize cross-axis sensitivity matrices across extreme temperature spans.
- Long Term Lifecycle Stability tracks obsolescence risks across discrete components, light-source operating life, and MEMS foundry wafer stability over ten-year procurement windows.
Extended lead times reflect ongoing optical and foundry supply constraints.
| Sensor Technology | In-Run Gyro Bias Stability | Accelerometer Non-Linearity K2 | G-Sensitive Drift Matrix | Unit Cost Index | Primary Sourcing Risk |
|---|---|---|---|---|---|
| Navigation Grade RLG | 0.002 to 0.005 Deg Per Hr | 10 to 30 Micro-g Per g-Squared | Less Than 0.001 Deg Per Hr Per g | 1.00 | Sole Source Mirror Optics and Gas Cavities |
| High Performance IFOG | 0.005 to 0.015 Deg Per Hr | 15 to 40 Micro-g Per g-Squared | 0.005 to 0.02 Deg Per Hr Per g | 0.75 | Specialty Optical Fiber and SLD Light Sources |
| Tactical Grade MEMS | 0.100 to 0.500 Deg Per Hr | 100 to 300 Micro-g Per g-Squared | 0.05 to 0.20 Deg Per Hr Per g | 0.15 | Foundry Wafer Process Changes and Drift Shifts |
Tactical MEMS gyroscopes offer compact footprints, low power consumption, and mechanical resilience, but suffer from pronounced g-sensitivity, scale-factor non-linearities, and thermal drift. Under polar base vibration, these uncompensated errors quickly swamp the attenuated horizontal Earth rate. Deploying MEMS for polar alignment requires extensive Kalman state augmentation alongside compliant isolators engineered to attenuate platform vibration above 20 Hertz.
Sourcing strategies must balance unit pricing against qualification schedules. Second-sourcing an optical gyro or MEMS accelerometer requires repeating multi-axis rate table runs, thermal profiling, and software calibration passes. Omitting dynamic motion testing during alternate-part qualification risks fielding systems vulnerable to severe rectification drift under actual arctic operating conditions.